ODDMETOD
Full title: Methods for defining, comparing and validating ODD and TOD for safe automated driving
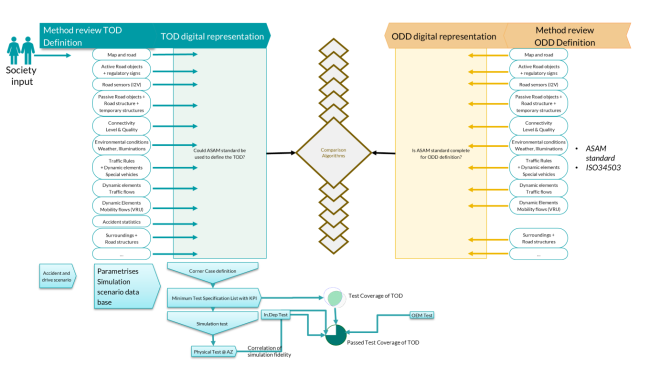
ODDmeTOD develops machine-readable methods to define a Target Operational Domain (TOD), compare it with a vehicle’s Operational Design Domain (ODD), and derive safety-critical scenarios and minimum test requirements. Demonstration in simulation and targeted physical tests creates a traceable evidence chain for approval, supporting safer deployment, efficient validation and international standardisation of automated driving.
Traffic safety benefit: Compares ODD and TOD to expose operational risk gaps and define safety-critical tests.
Connection to other projects: SAFRAN and EVIDENT
Key words: ODD, TOD, automated driving, safety validation, ASAM OpenODD