Project portfolio
EVOROADS
Full title: Evolutionary Solutions for Realising a Holistic Safe System Approach for All Road Users The successful implementation of EU’s 2021-2030 road safety policy is a milestone towards the target of zero fatalities in
PREKO 2
Full title: Proactive assessment of cognitive work environment in ambulance healthcare (Proaktiv bedömning av kognitiv arbetsmiljö i ambulanssjukvården) This project intends to improve the conditions for understanding and
TWIN-SAFE
Full title: Advancing Road Safety through Twinning The TWINSAFE project aims to enhance road safety research capabilities at the University of Zagreb, Faculty of Transport and Traffic Sciences (FTTS) by fostering
SYNERGIES
Full title: Real and synthetic scenarios generated for the development, training, virtual testing and validation of CCAM systems The main goal of Synergies is to fully enable development, training, virtual testing and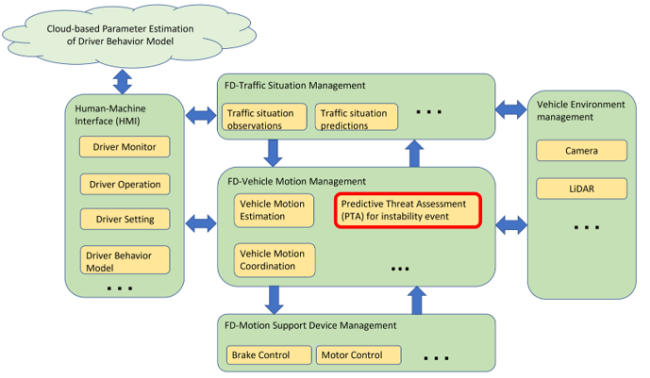
PREDICTIVE THREAT ASSESSMENT FOR ENHANCED STABILITY OF MULTI-UNIT HEAVY VEHICLES
The objective of this research project is to improve the effectiveness of Advanced Driver Assistance Systems (ADAS) for Multi-Unit Heavy Vehicles (MHVs), by providing them with tools that enable earlier, more effective, and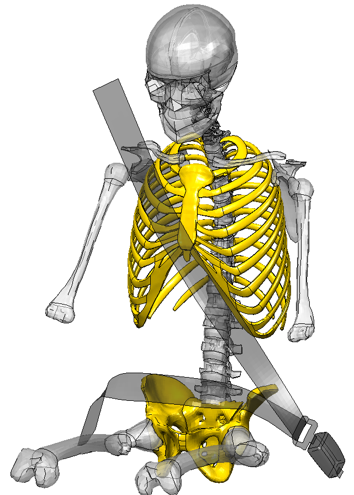
Injury HBM, step 5
Full title: Enhancing Female and Male SAFER HBM Torso Injury Prediction (I-HBM V) Abstract: Expecting a greater variation in occupant sitting postures and activities in future vehicles, continued development of occupant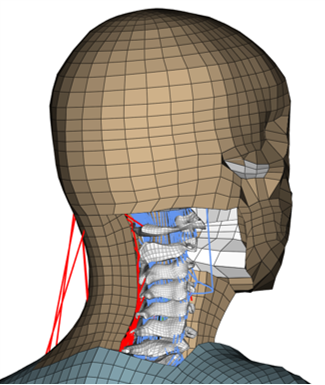
SAFER HBM Neck Injury Prediction
Full title: Advancing Neck Injury Prediction in Car Crashes using the SAFER HBM Abstract: The cervical spine (neck) is a complex body region that can be exposed to a variety of injury consequences, ranging from high severity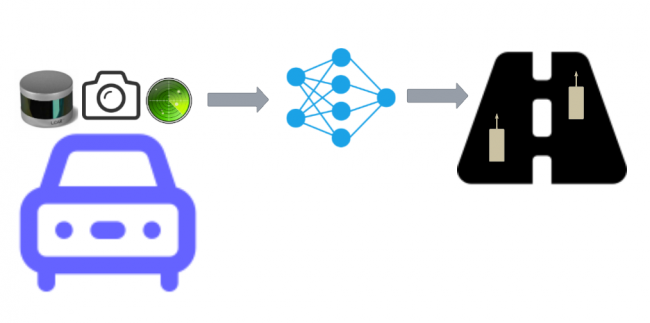
DEEP MULTIMODAL LEARNING FOR AUTOMOTIVE APPLICATIONS
This project aims to create multimodal sensor fusion methods for advanced and robust automotive perception systems. The project will focus on three key areas: (1) Develop multimodal fusion architectures and representations
REALLOCATE - Rethinking how we move
REALLOCATE transforms streets into inclusive, green, safe and future-proof urban spaces, where communities live and thrive. The project enables researchers, mobility experts, urban planners and local citizens to collectively
SUperSAFE
Full title: SUrrogate measures for SAFE autonomous and connected mobility SUperSAFE ‘SUrrogate measures for SAFE autonomous and connected mobility’ will address the problem of the safety evaluation of the interaction between