
Project portfolio
DCAS Users
The project will combine results and user opinions from the Skyltfonden/Cognitian project “SupportIN – Improved user experience for driver support” with the requirements in UNECE R171 regulation. The goal is to identify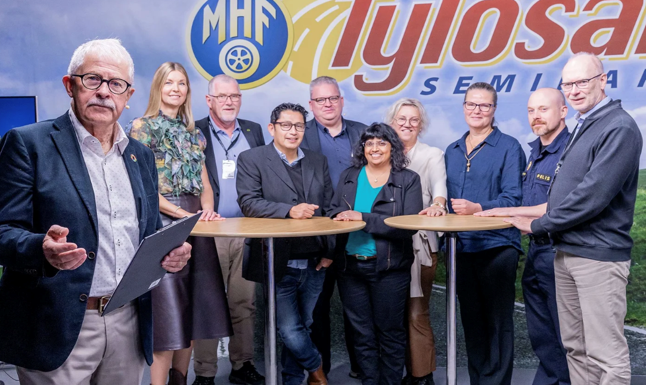
Tylösand Seminar Studio
Since 1957, MHF has held the Tylösand Seminar as a national meeting place for traffic safety actors. In recent years, the digital format Tylösand Seminar Studio has been developed, and seven national broadcasts have been
Power gathering of tuned electric scooters and review of sales
Swedish title: Kraftsamling trimmade elsparkcyklar och granskning av försäljning In 2026, MHF will measure the speed of electric scooters. This applies to both private and rental vehicles. This will be done in a total of 20
RISK ASSESSMENT IN VLA MODELS
Full title: Risk assessment in vision-language-action models for autonomous driving This project studies risk assessment in vision-language-action models (VLAs) used for automated driving (AD). Modern AD systems rely on deep
Banning electric fatbikes?
Full title: Banning electric fatbikes? Biomechanics and injury risk. (Förbud mot elektriska fatbikes? Biomekanik och skaderisk.) Electric fatbikes are increasingly popular. However, their vehicle design and potentially higher
Evaluation of ISA on state roads
Full title: Evaluation of ISA on state roads using A-to-B speed data This ongoing field study will assess how Intelligent Speed Assistance (ISA) relates to actual driving speeds on a state-road section with an 80 km/h limit
National quality assurance project for alcohol interlocks
Full title: National quality assurance project for alcohol interlocks – method support and implementation (Nationellt kvalitetssäkringsprojekt för alkolås – metodstöd och implementering) The project's hypothesis is that the
FUSE4CCAM
Full title: Federated Unified Services advancing next generation - data exchange for CCAM European Cooperative, Connected and Automated Mobility (CCAM) is generating vast and growing volumes of data — from field operational
Communication for safe and active mobility
The project aims to contribute to safe and active mobility through information and knowledge-raising communication efforts, which will strengthen the national traffic safety work and help the transition to more people
Full Body SSM and Morphing
Full title: Human Body Model Morphing for Safety Assessment Across Occupant Variability and Seating Postures Vehicle safety assessment has long relied on a limited set of standardised anthropometries, despite large real‑world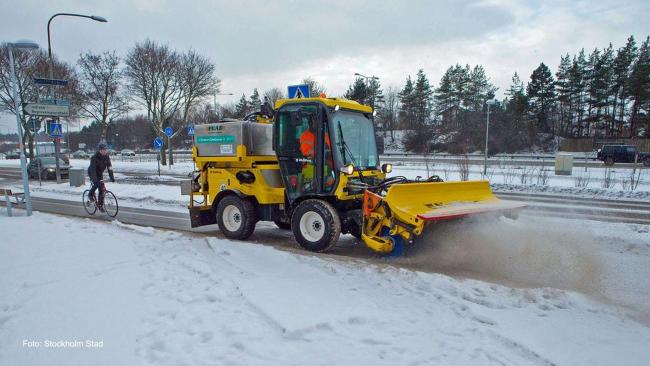
Sweep-salting
Full title: Effects of sweep-salting on cyclist and pedestrian crash risk Sweep-salting is increasingly used on Swedish pedestrian and bicycle routes to improve winter conditions, but its effect on traffic safety is still not
CONNECTED VEHICLE DATA
Full title: Pilot project on the traffic safety benefits of connected vehicle data Connected vehicle data is already used to some extent in Swedish traffic operations, but its potential for road safety has not yet been
SAFIRA
Full title: Safira Score – validating a business model for traffic safety certification of heavy transport Euro NCAP Safer Trucks rates new truck models – it does not certify individual vehicles. Trucks in service are often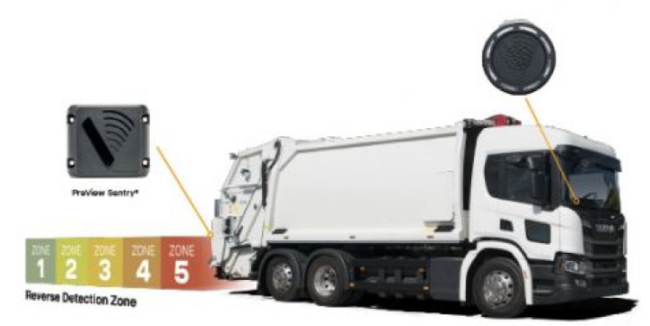
Reverse safely
Full title: Reverse safely – focus on heavy trucks in urban environments (Backa säkert – fokus på tunga lastbilar i stadsmiljö) Reversing heavy trucks are a recurring risk to pedestrians, cyclists and workers in urban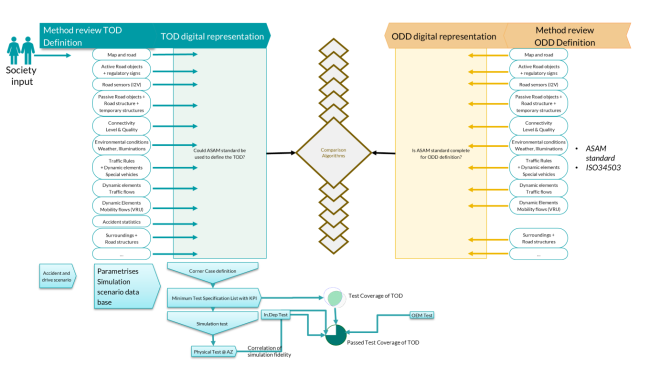
ODDMETOD
Full title: Methods for defining, comparing and validating ODD and TOD for safe automated driving ODDmeTOD develops machine-readable methods to define a Target Operational Domain (TOD), compare it with a vehicle’s Operational
COREDAC
Full title: Cost and Resource Efficient Data Collection (CoREDaC) The CoREDaC project aims to develop a cost- and resource-efficient data acquisition technology for Advanced Driver Assistance Systems (ADAS) and Autonomous
Be-Point
Full title: Towards a driver behavioural point of no return (Modellering av förarbeteendedefinierad "point of no return") This pre-study investigates the concept of a behavioural point of no return—the point at which a driver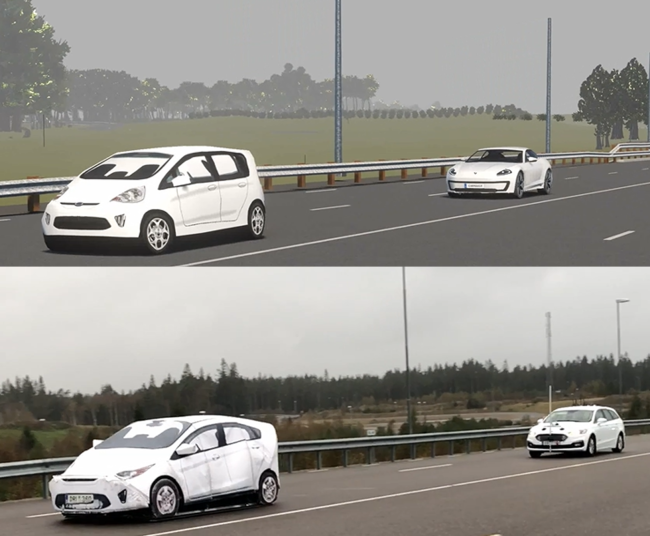
EVIDENT 2
Full title: Enabling VIrtual valiDation and vErificatioN for adas and ad feaTures #2 EVIDENT 2 aims to increase trust in simulation and enable reliable virtual verification and validation of ADAS and AD systems. It develops
PRESTO
Full title: PRedictable Emergency Safety and Traffic Operations Rapid emergency response is crucial for reducing the consequences of traffic incidents, yet emergency vehicles operate in highly dynamic traffic environments
Remote Ready Move
Full title: Advancing Technical and Societal Readiness of Remote Operation in Connected, Cooperative, and Automated Mobility (CCAM) Services for People and Goods - HORIZON-CL5-2025-04-D6-01 The aim of RemoteReadyMove is to